Give robots a
sense of touch.
E-skin sensors that turn physical contact into precise tactile data.
Tactile intelligence
Bring human-level dexterity to robots through tactile intelligence.
Carus AI is a full-stack platform for embodied AI dexterous skills. Built on in-house tactile sensor systems, we close the loop from dexterous data-collection hardware and dexterous data to dexterous skills and real-world deployment.
Demo videos
From human touch
to robot skill.
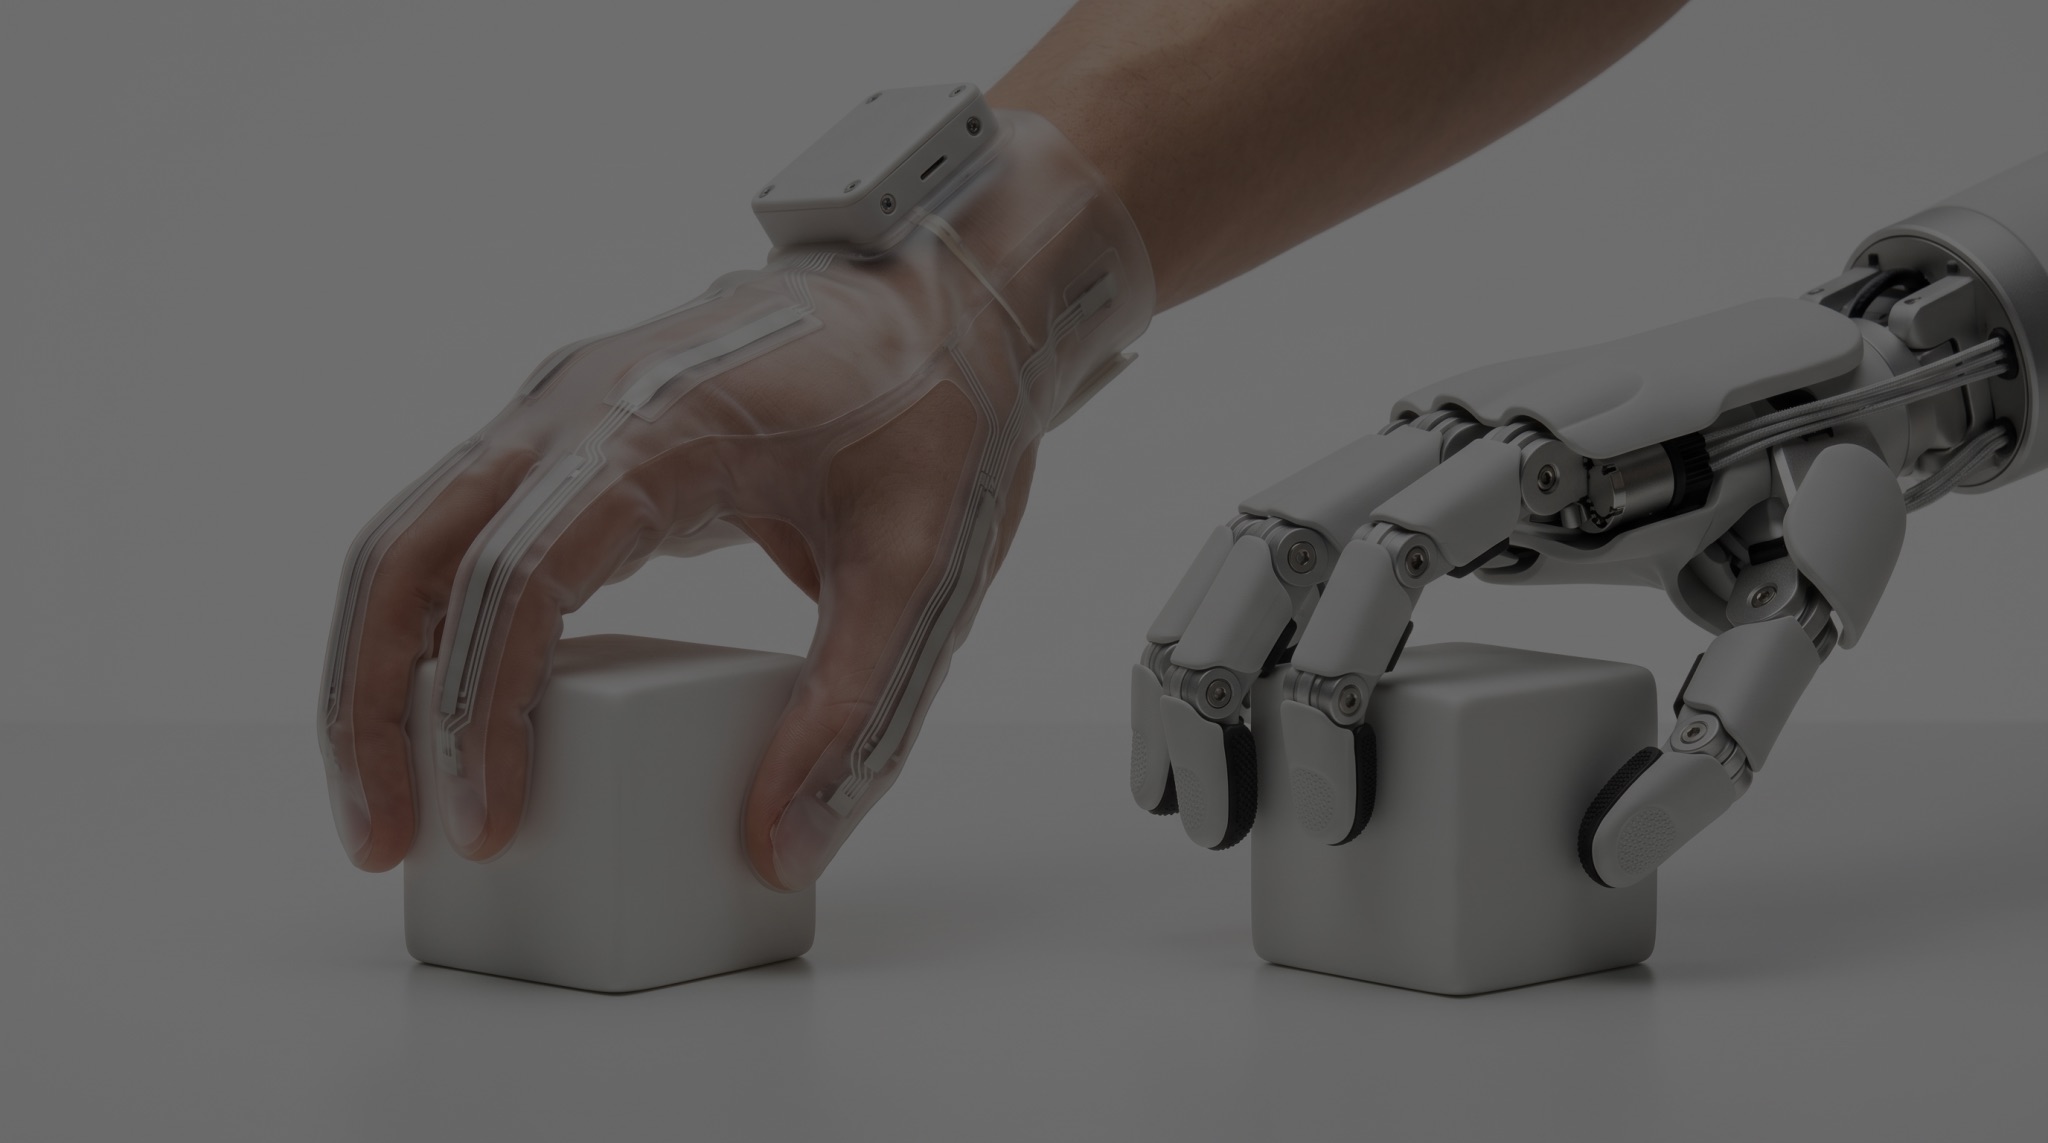
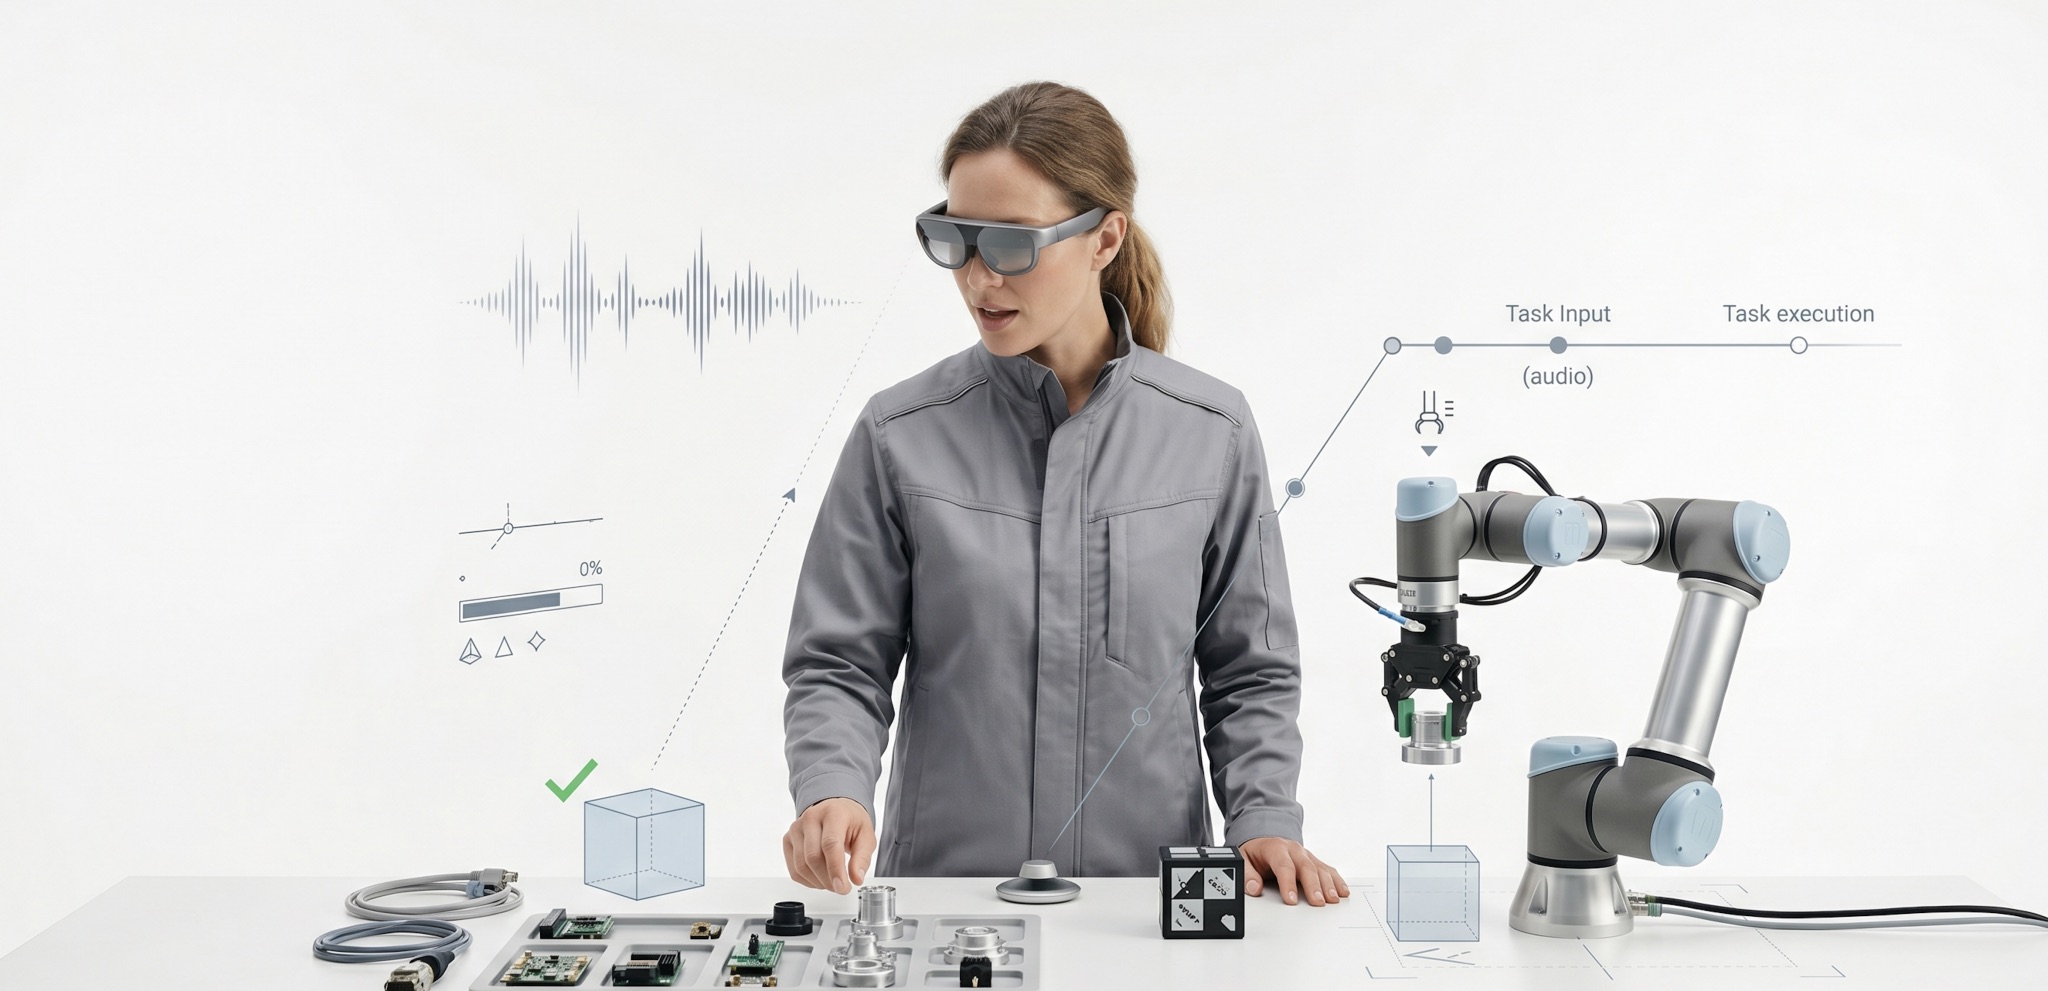
Human demonstration, robot execution
Dual-source data: people show it once, robots learn to repeat it.
Sensor
Every contact
becomes data.
Flexible tactile e-skin for robot hands and gloves. It maps where contact happens, how hard, and how it changes over time — the signal robots need for adaptive, force-aware grasping.
- FPS-01 Tactile E-SkinFlexible
- Hybrid E-SkinHybrid architecture
- Flexible Tactile E-SkinRobot hands
- Fabric Tactile Sensors & GlovesTextile
Simulation · Pinch
Press a fingertip
Products
Built for dexterity.
Sensors, hands and capture hardware, designed to work together.
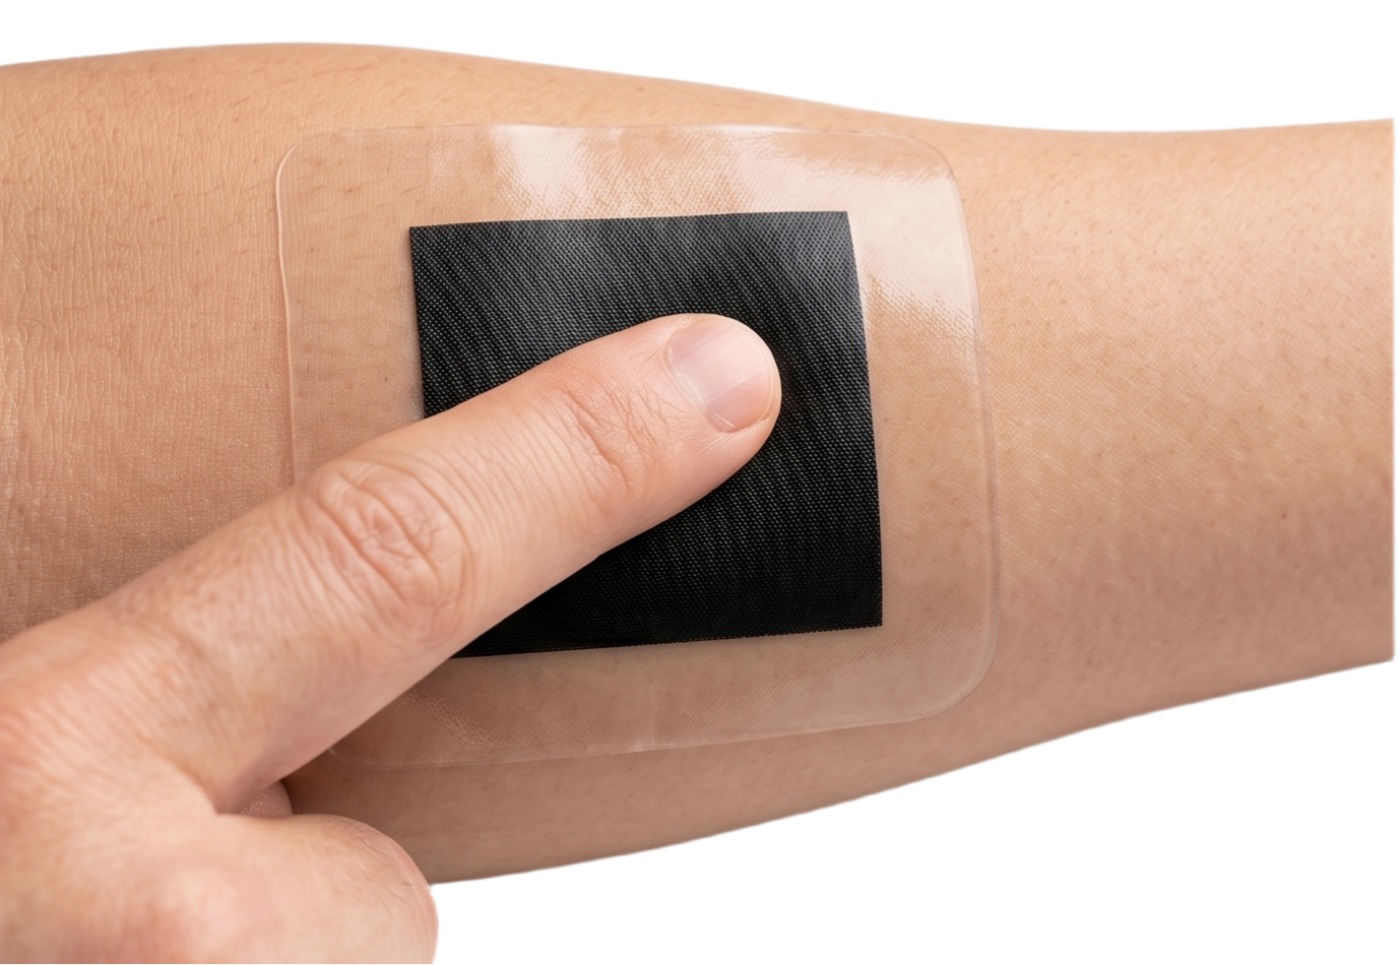
FPS-01 Tactile E-Skin
Flexible tactile e-skin
Request specs
Hybrid E-Skin
Hybrid e-skin architecture
Request specs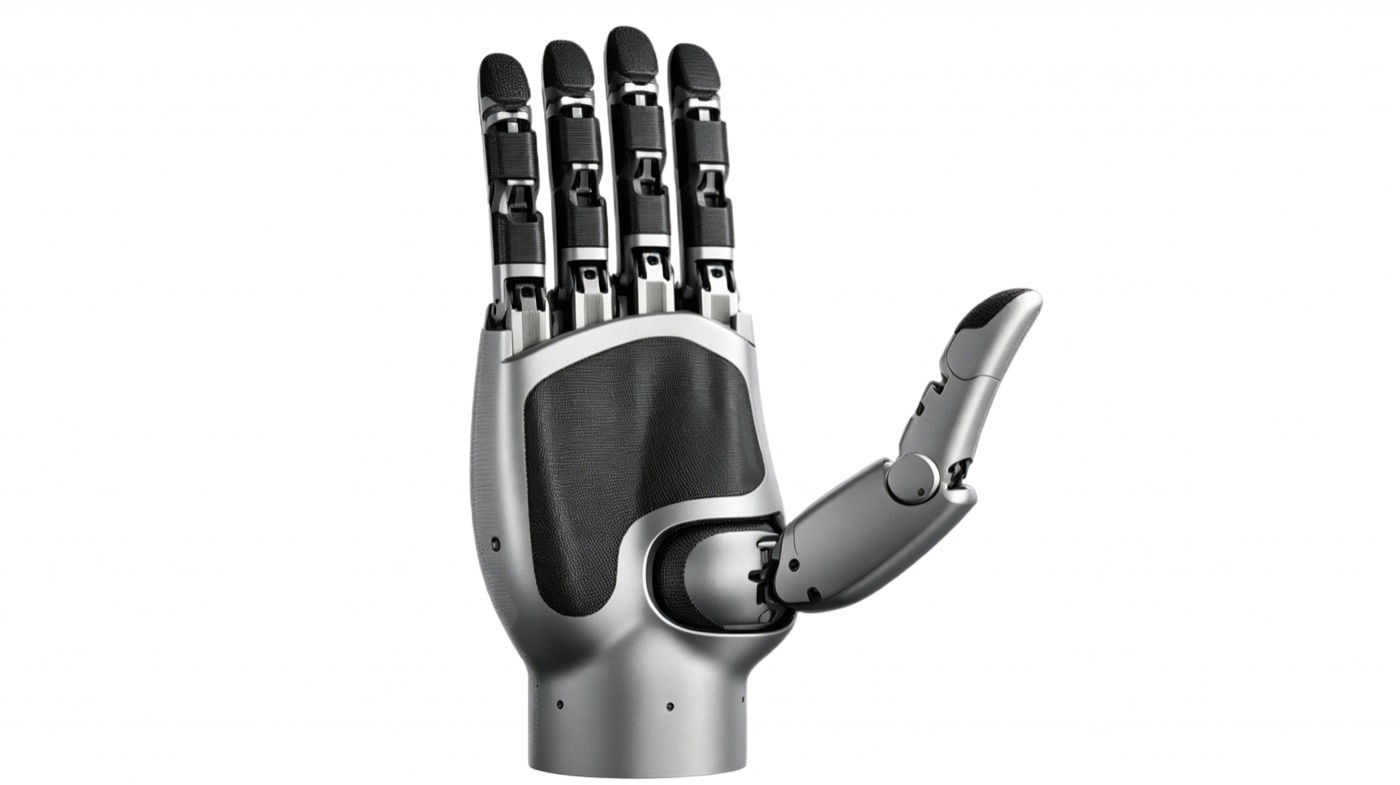
Flexible Tactile E-Skin
E-skin for robot hands
Request specs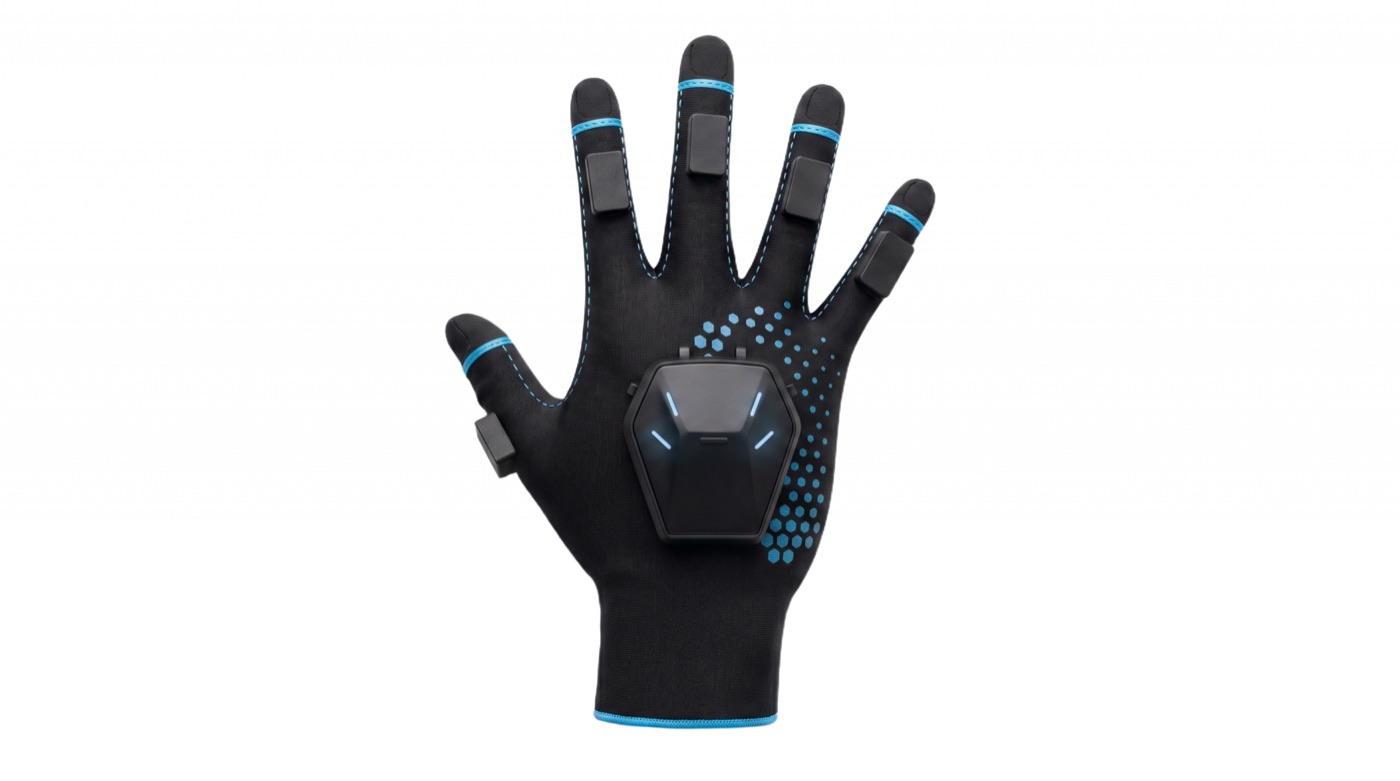
Fabric Tactile Gloves
Textile tactile glove solution
Request specsFlex Hand F25
Flexible dexterous hand
Request specs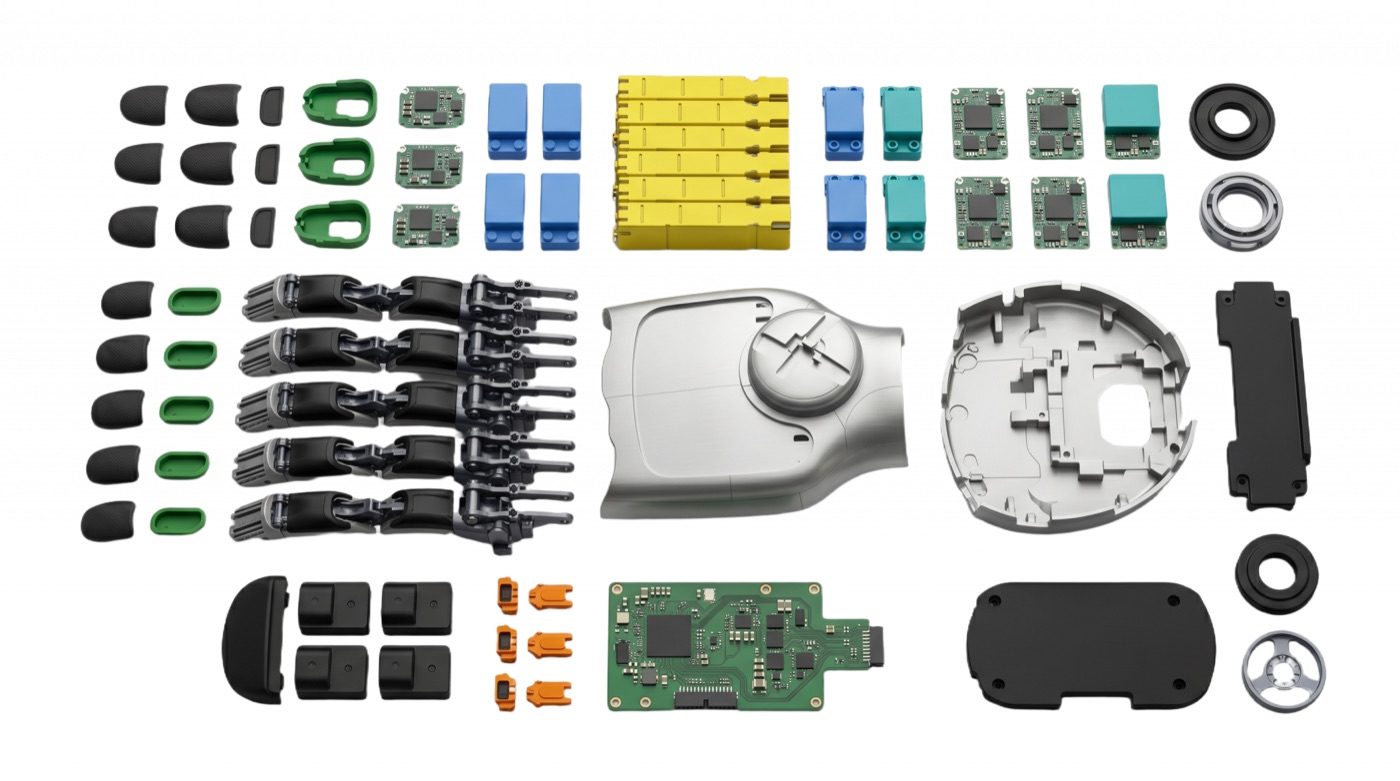
Linkage L22
Linkage-driven dexterous hand
Request specs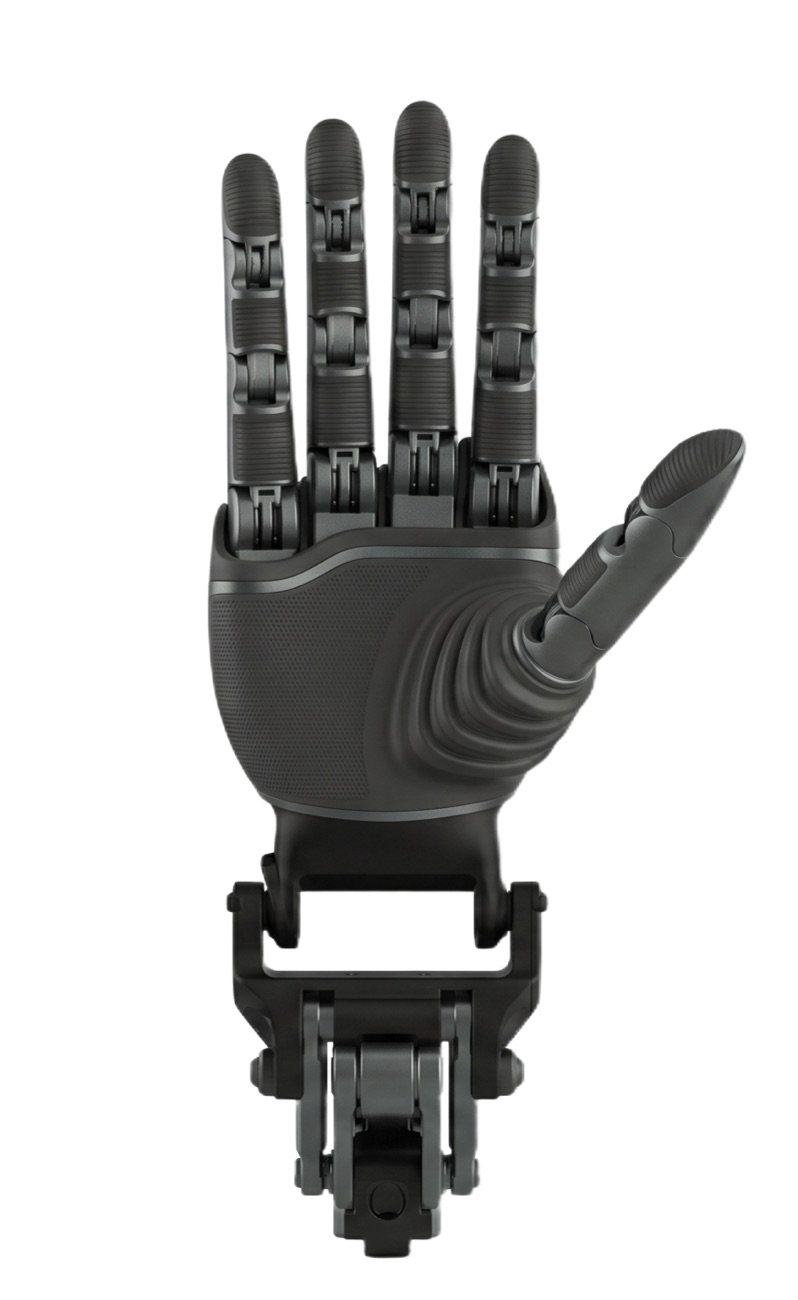
Tendon-Driven TD17
Tendon-driven dexterous hand
Request specs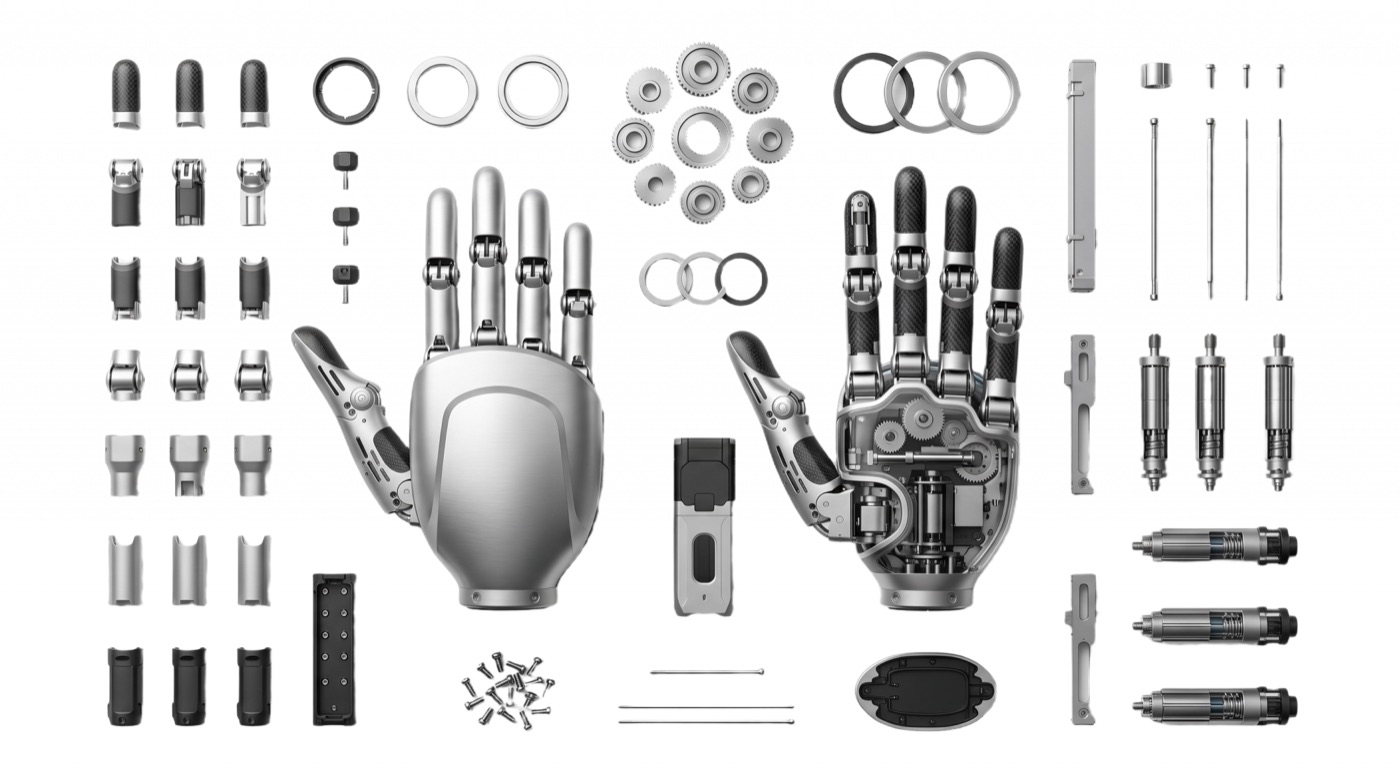
Direct-Drive DD16
Direct-drive dexterous hand
Request specs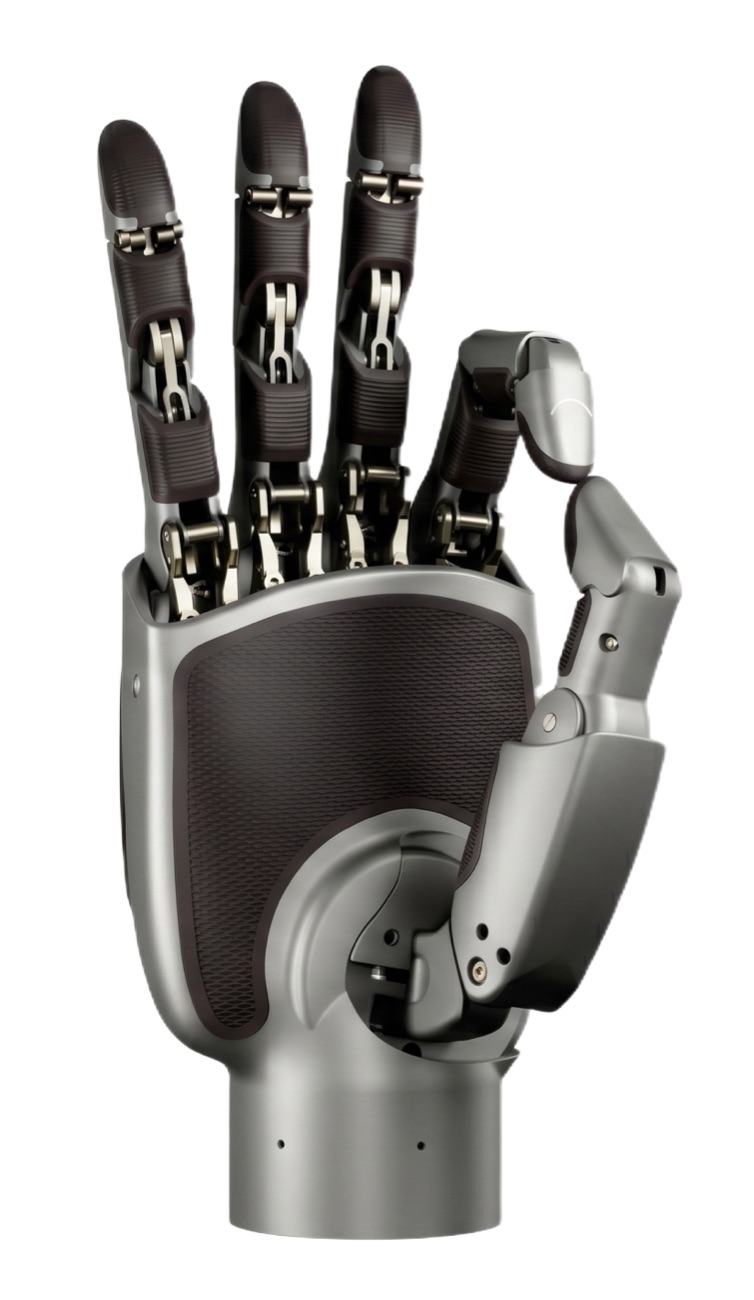
Linkage-Driven Hand
Dexterous hand
Request specs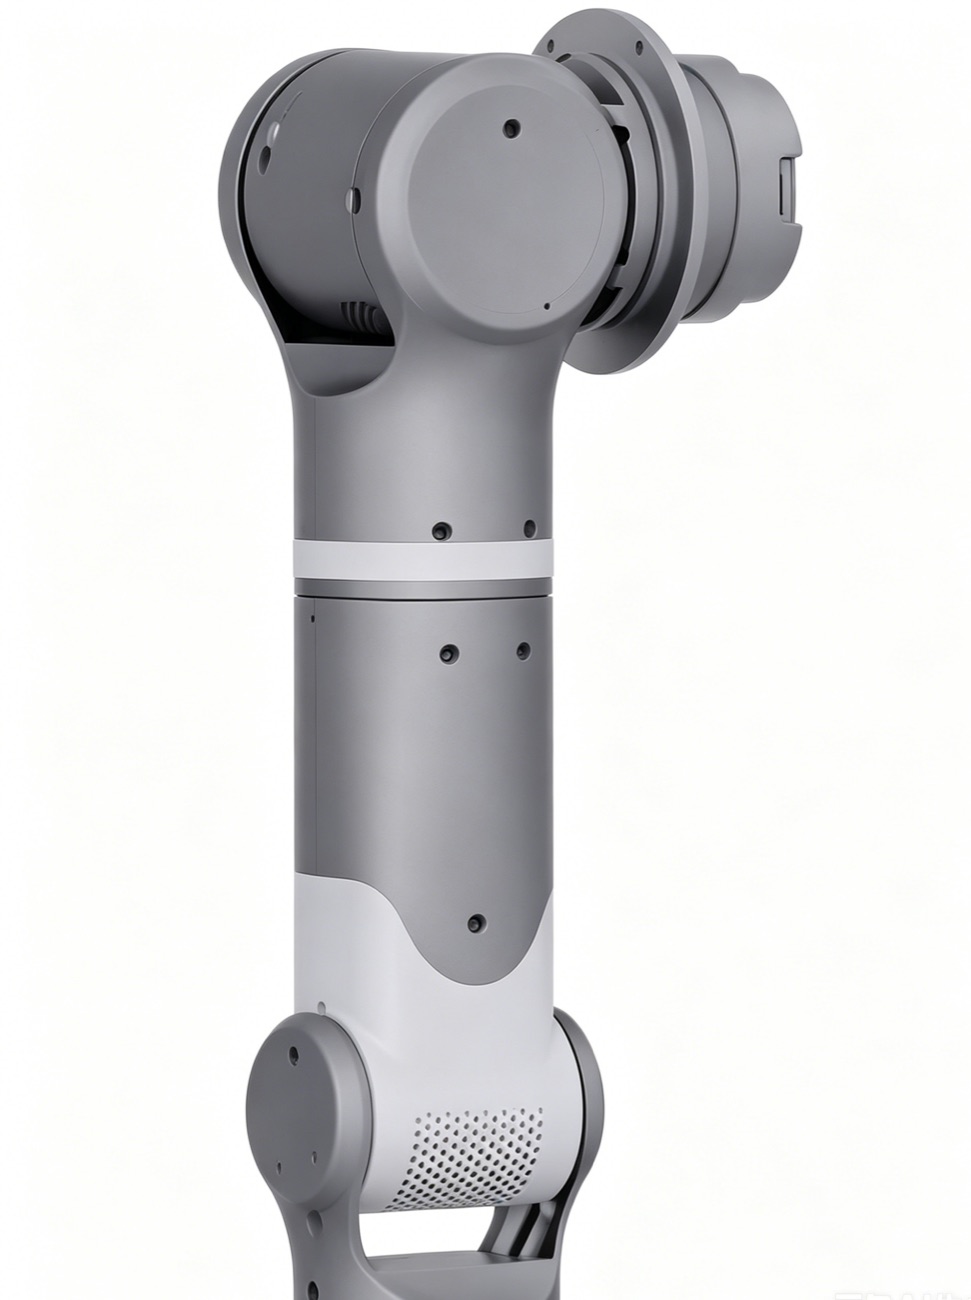
Collaborative Robot Arm
Robot arm
Request specs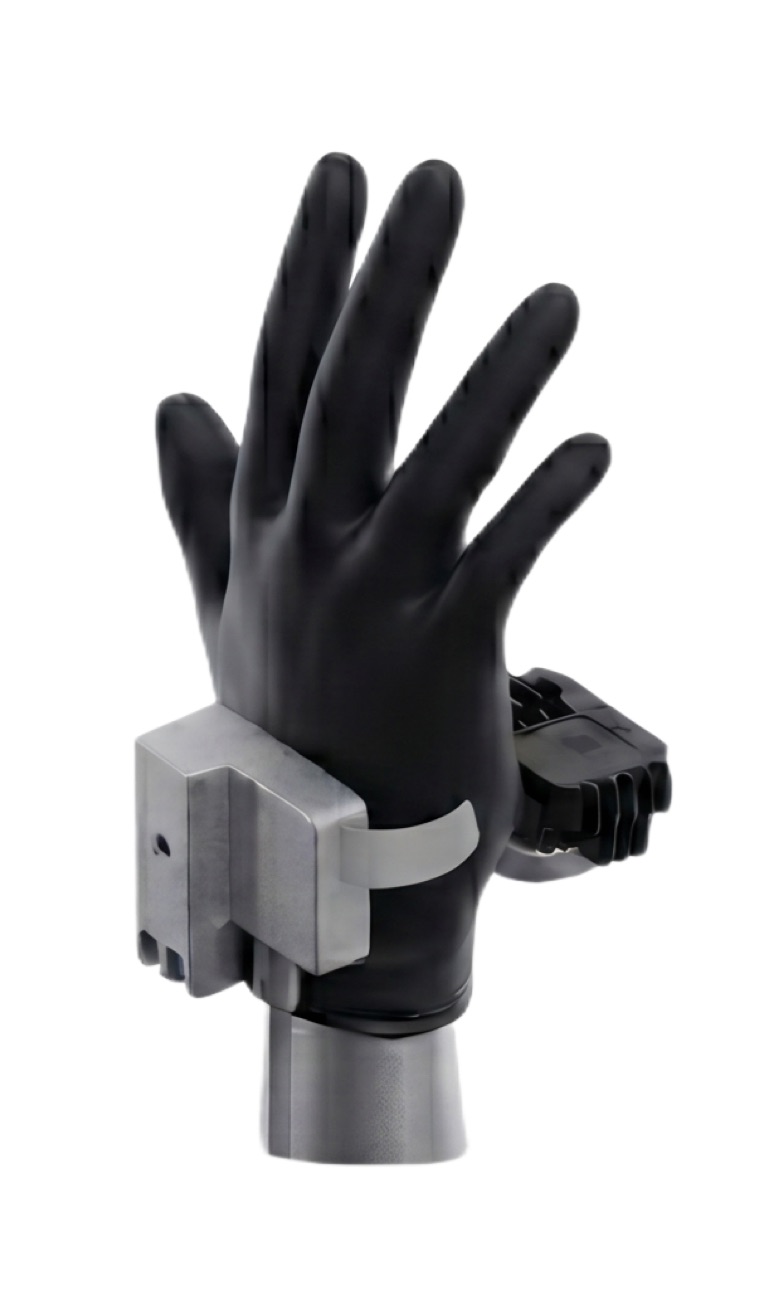
Data
From human hands
to robot skills.
A closed loop from dexterous data collection to deployable skills, bridging human demonstration and robot execution.
-
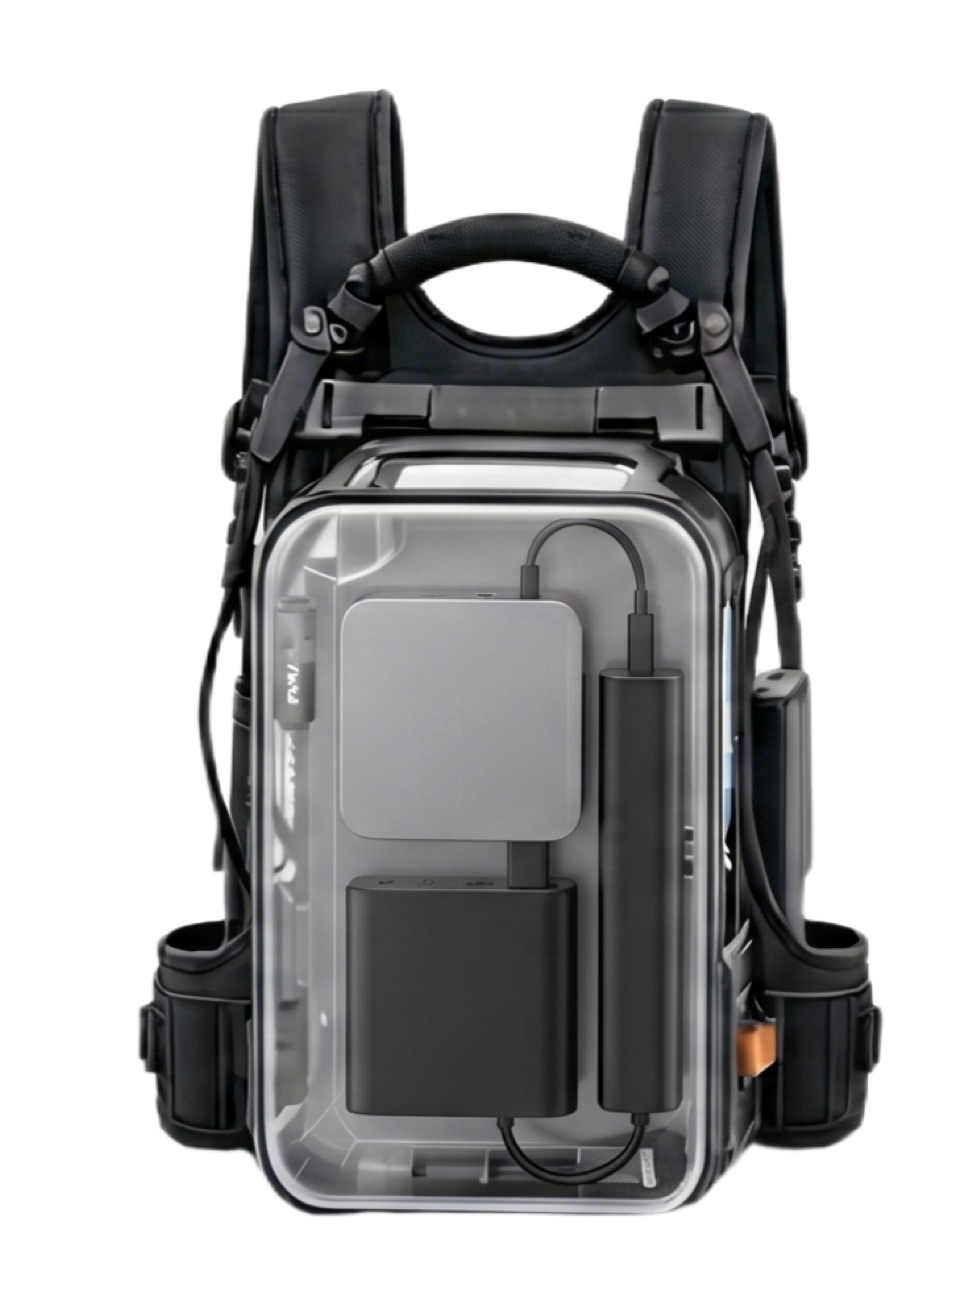
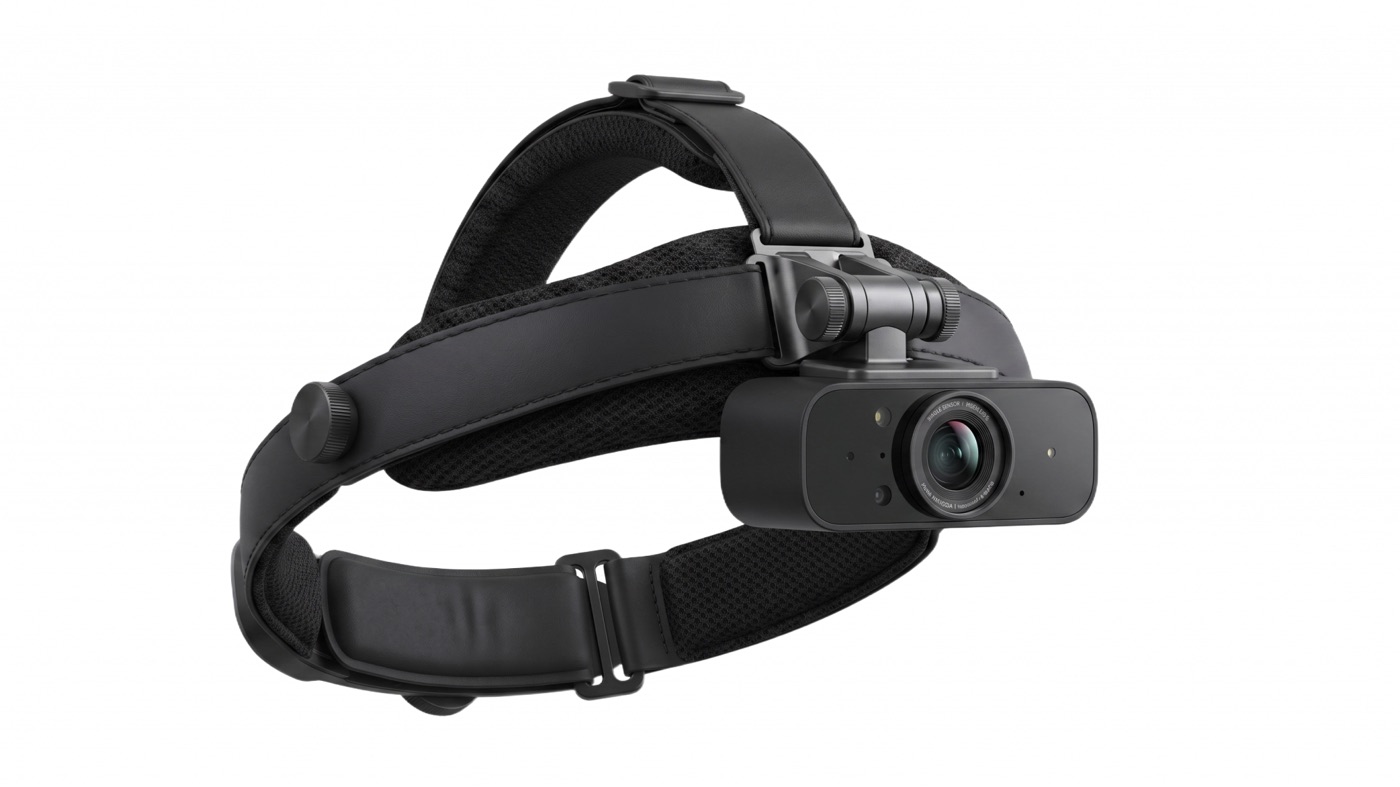
01 — Capture
Vision-tactile-motion hardware
Glove body, collection backpack and head vision system record how people really manipulate objects.
-
02 — Structure
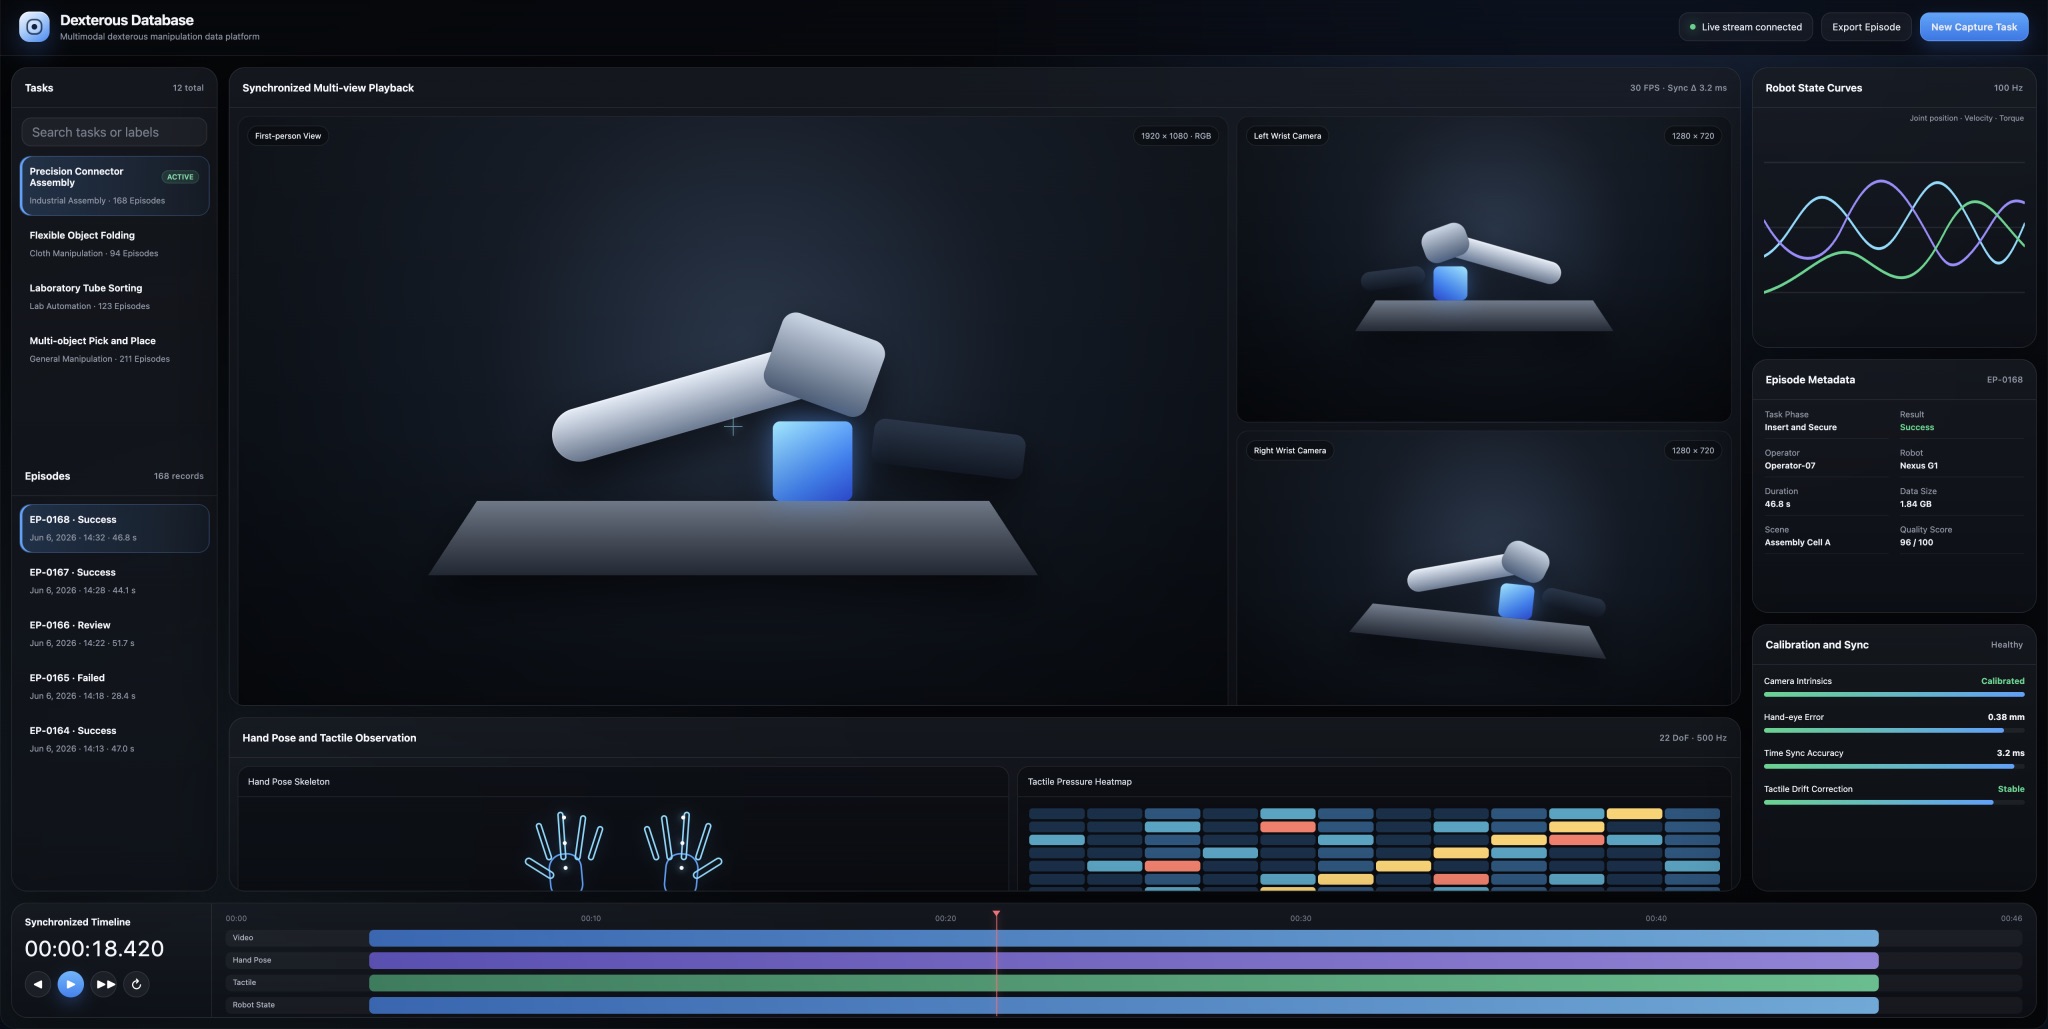
Multimodal dexterous database
Multi-view vision, hand kinematics and robot joint state, tactile and force sensing, task semantics and temporal annotation.
-
03 — Deploy
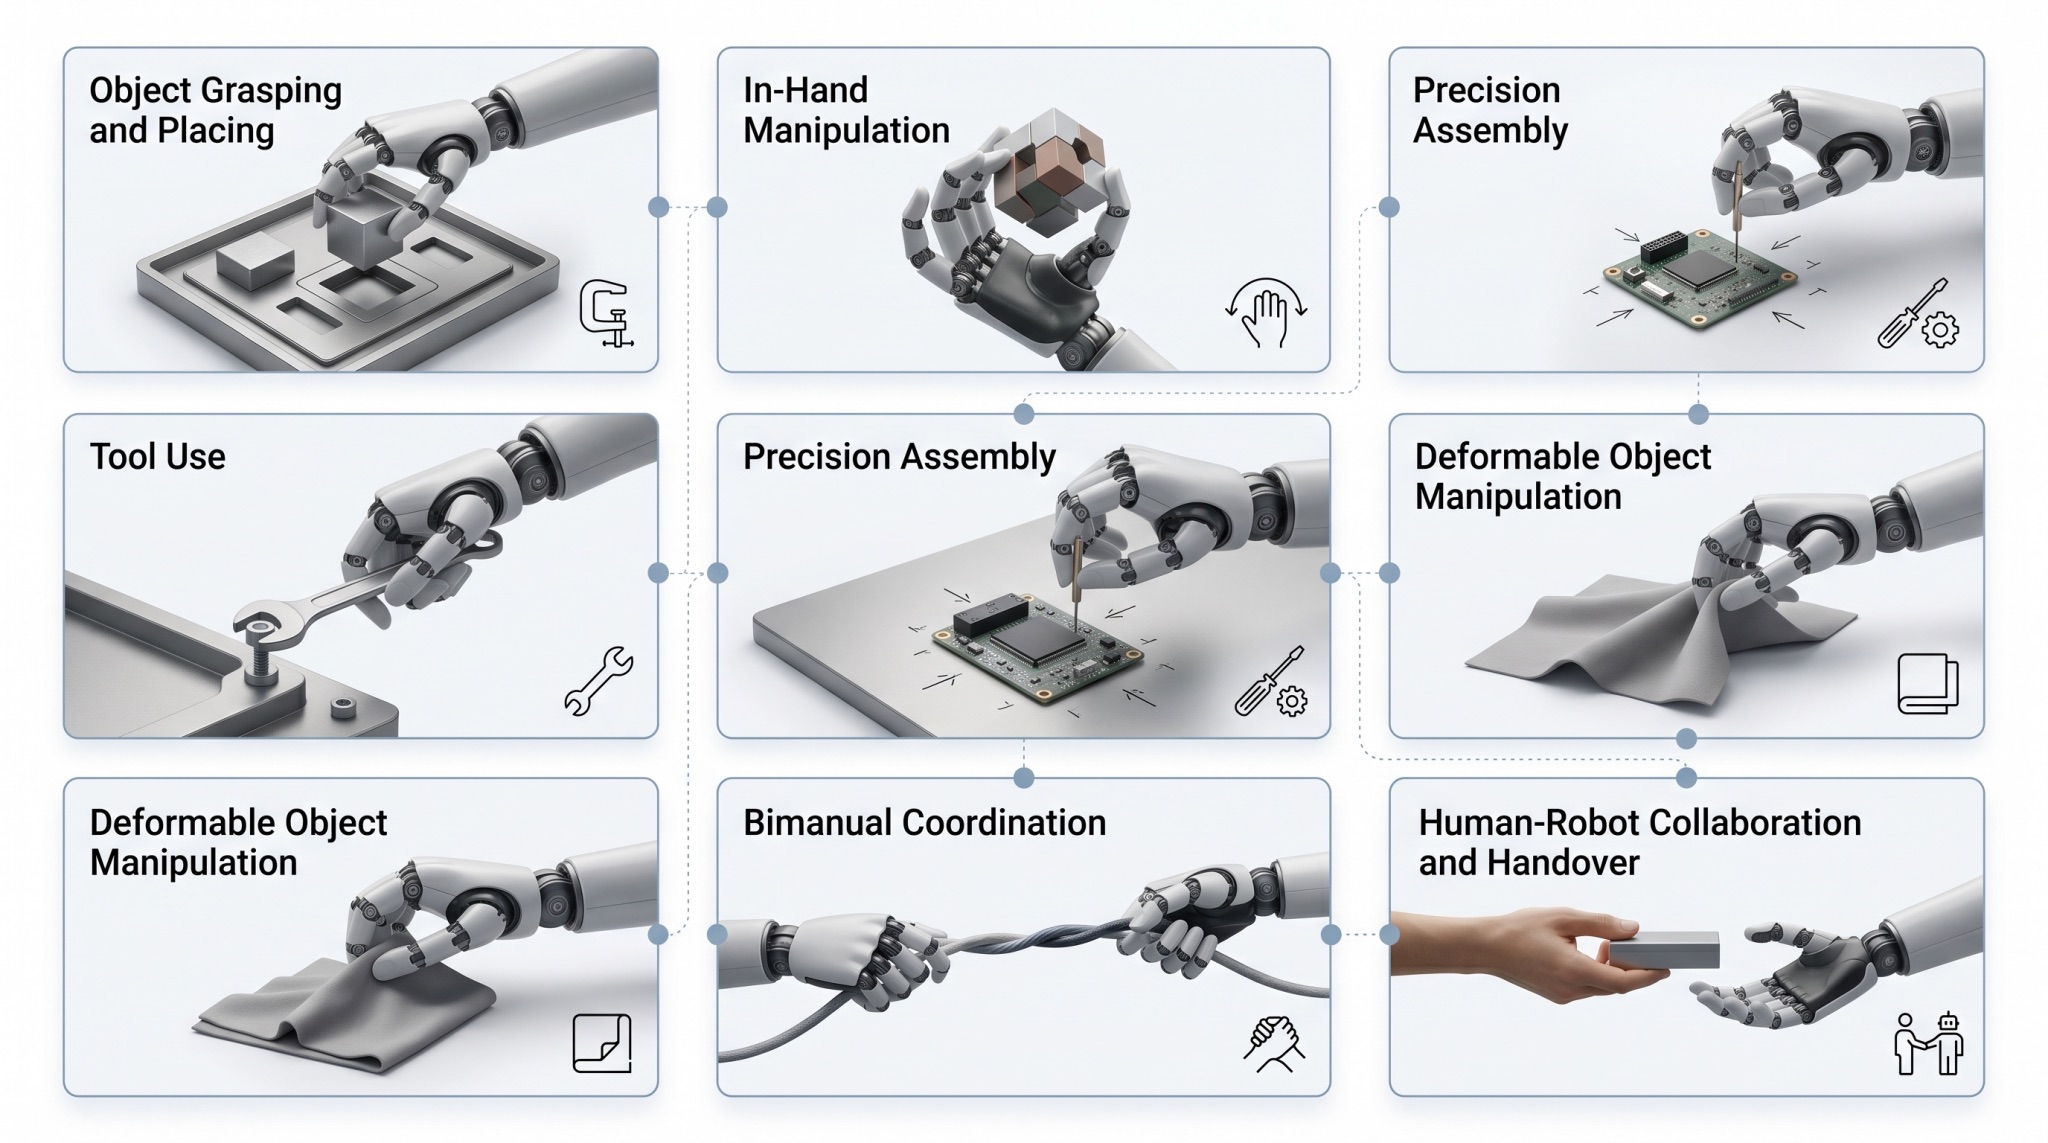
Skills for real-world tasks
Pick and place, in-hand manipulation, precision assembly, tool use and bimanual work, served through one API.
Human demonstration data
Embodiment-agnostic. Accumulates fine manipulation priors at scale and transfers across platforms.
Robot execution data
Teleoperated platforms capture the full perception → decision → execution pipeline, aligned to specific action spaces.
Dual-source synergy · pre-training · fine-tuning · evaluation · cross-embodiment transfer
Standardized datasets
Cleaned, annotated and structured for model training and evaluation.
Custom collection
Targeted data collection for specified tasks, scenes and robot platforms.
Training data engineering
Action conversion, episode curation and training-format adaptation.
Data governance
Quality assessment, version control and private data management.
API
Call a skill.
Skip the rebuild.
From perception to execution, one interface — open to foundation models, VLAs, policies and planners.
- 01Object detection
- 02Pose estimation
- 03Grasp generation
- 04Pick & place
- 05Object reorientation
- 06Precision insertion
- 07Button pressing
- 08Switch & knob
- 09Tool manipulation
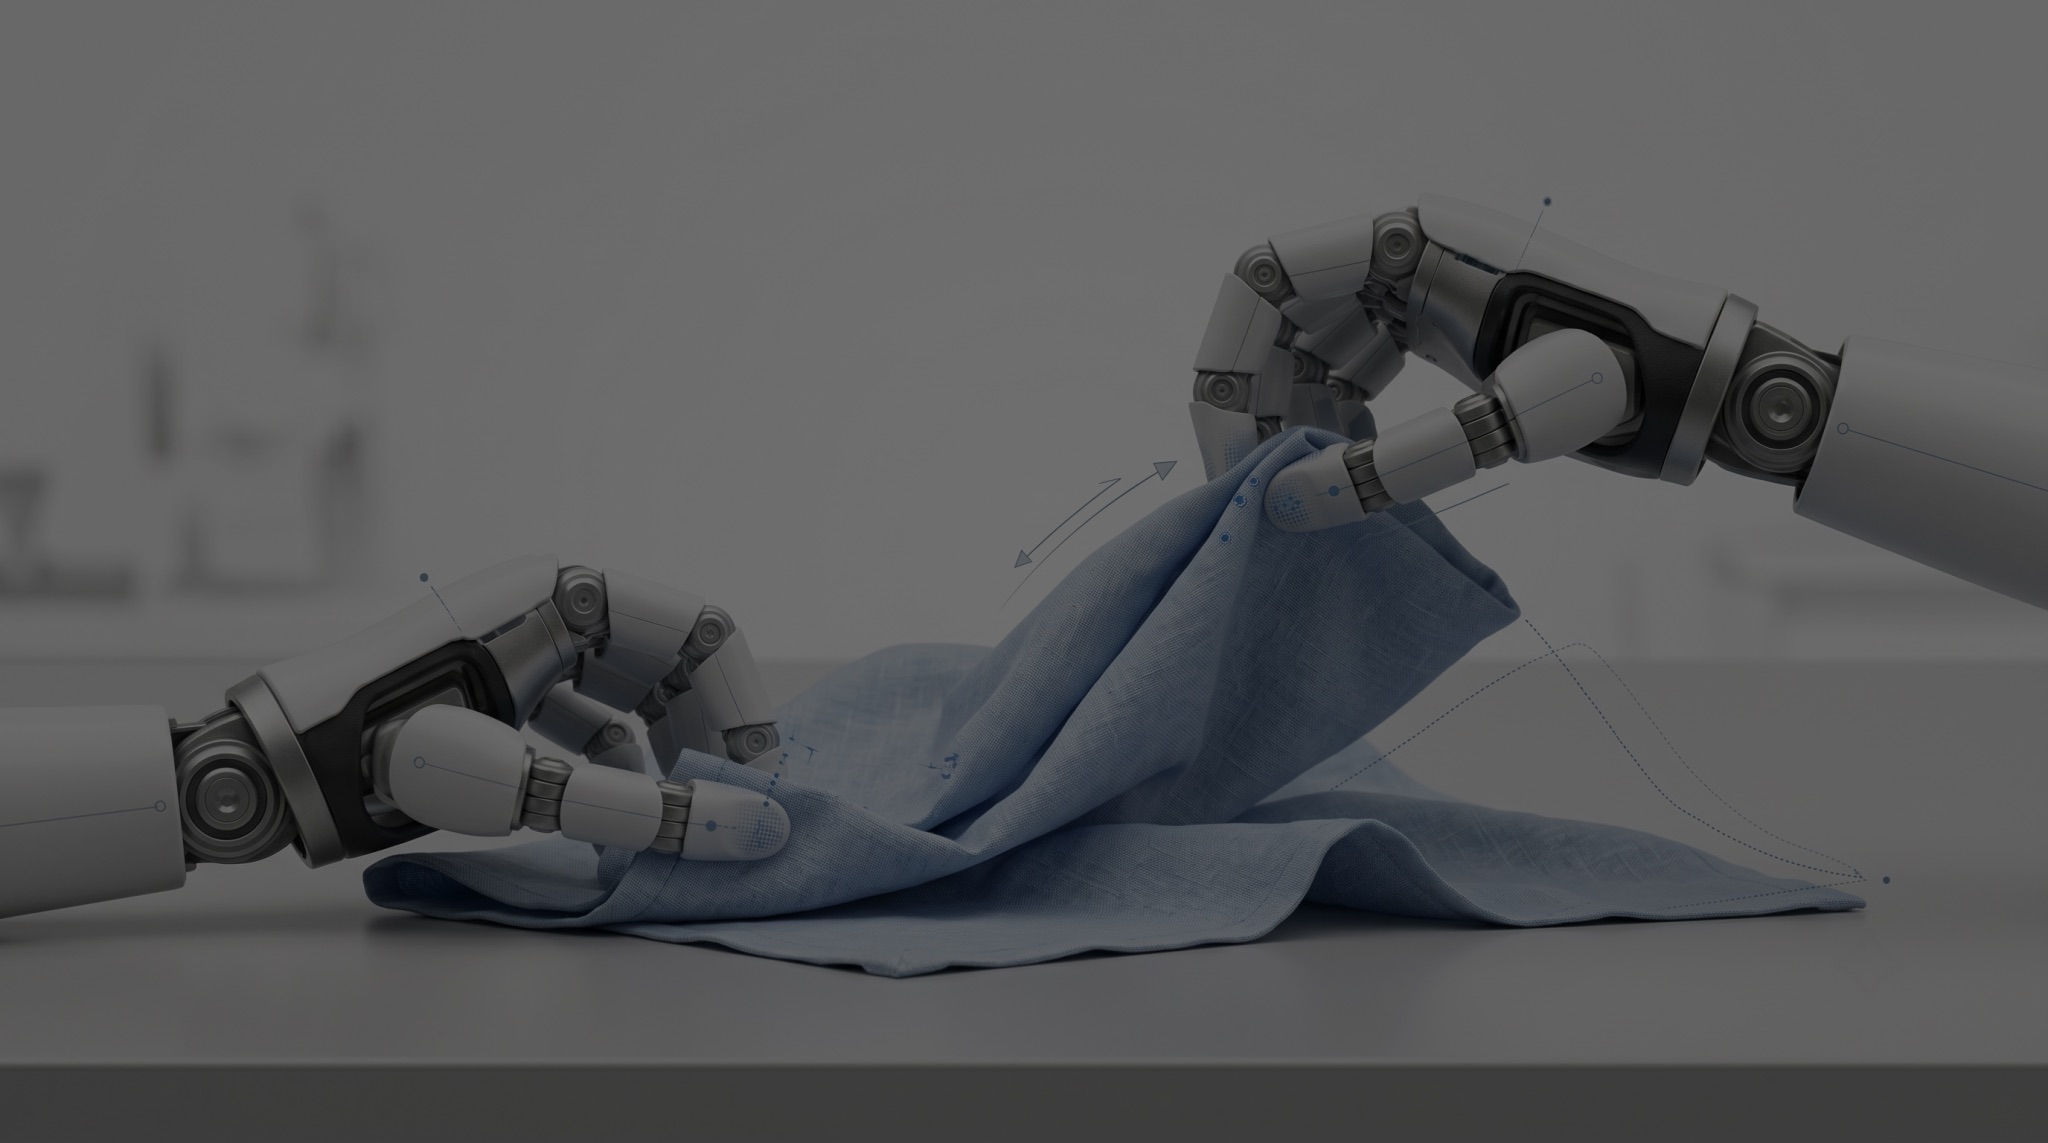
- 10Deformable handling
- 11Bimanual manipulation
- 12Human-robot handover
- 13Tactile grasping
- 14Skill status query
- 15Abort & recover
Composite tasks — multiple skills, one execution
Smart sorting
- Detect
- Grasp
- Classify
- Place
- Confirm
Precision assembly
- Locate
- Adjust
- Align
- Insert
- Force-verify
Bin packing
- Select
- Bimanual grasp
- Transfer
- Pack
- Review
Model & agent integration
- Robot foundation models
- Vision-language-action models
- VLMs & multimodal LLMs
- Imitation learning & policies
- Reinforcement learning & world models
- Motion planning & control
- Multi-agent & task planners
- Custom enterprise models
About
Our vision: build the world’s most valuable dexterous data platform for Physical AI.
Contact
Put a sense of touch in every robot hand.
Tell us what your robots need to handle — sensors, hands, data or skills.